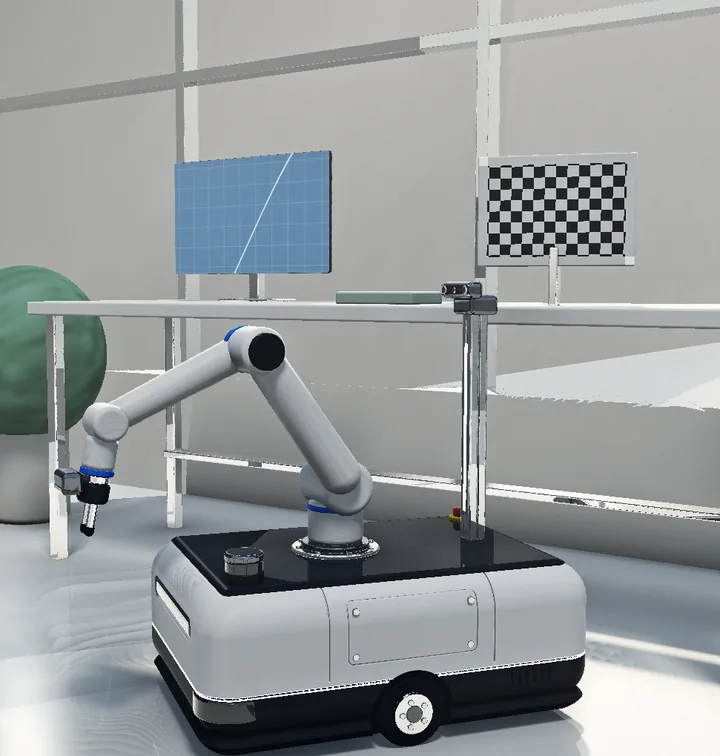
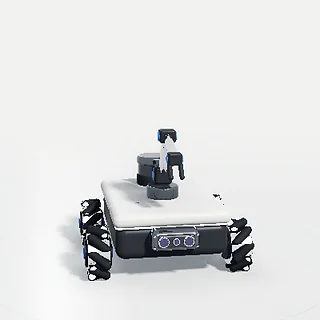
Mobile manipulator
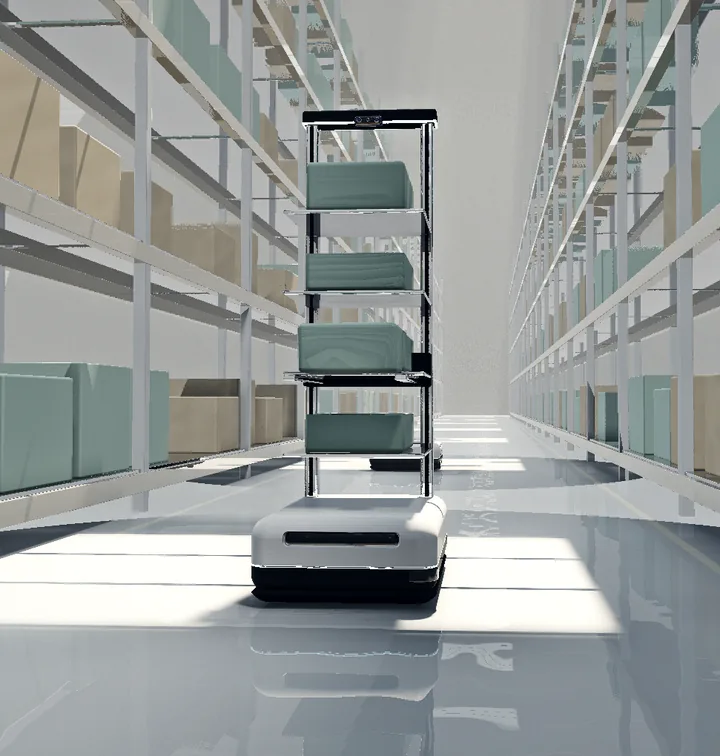
 Tote-handling robot
 Lift AMR
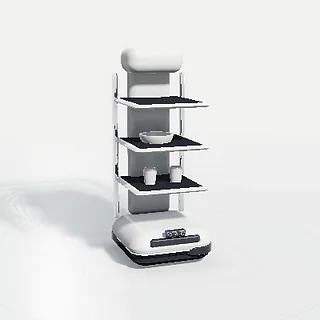
 Hotel service robot
 Delivery robot
 Education robot
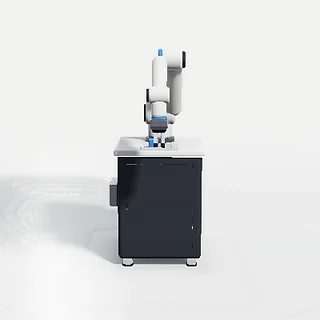
 Vision cobot cell
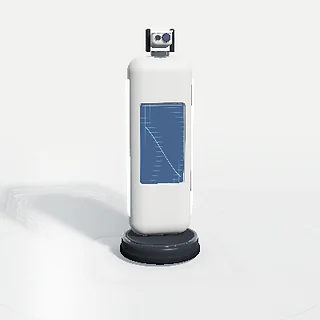
 Guide and inspection robot

Vision & Depth Cameras
TR-CAM-S4M · TR-CAM-U4MStereo depth cameras turn two views into depth for grasping and obstacle checks.
- Working distance and field of view for the task
- Lighting and surface texture at the site
- Driver and SDK on your host OS
Selection & Sourcing
Not sure which part fits, how to confirm it, or where to buy it? Choose a path. Product quotes stay free.
Find my pathSee sample workAbout TANNAI FreeFree Product QuoteA quote reply for your models, quantity and region — or the questions we still need answered.
 US$199Technical Fit ReviewA document-based review of one robotics hardware question: up to three candidates, evidence-linked comparison, risks and a purchase checklist.
 US$590Sourcing SprintEvidence-led comparison of the supply paths behind one hardware need or small BOM: identity, variants, terms to confirm and a buyer question set.
The page stays the same; only the language changes.
Explore robot configurations for different tasks. Send us your project needs for a tailored selection.
Turn each concept through 360° in 10° steps: drag, swipe or use the arrow keys.
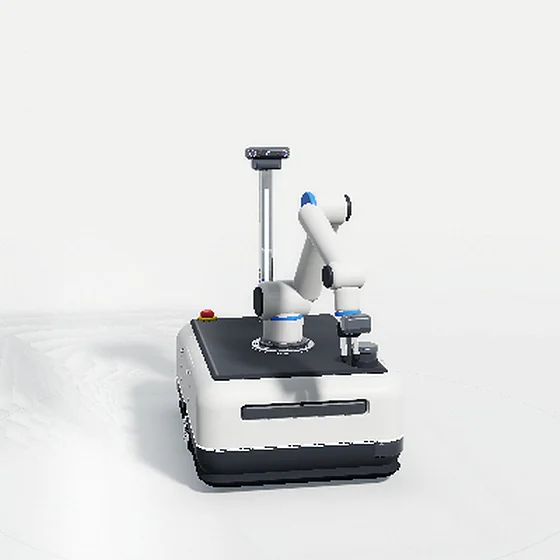 Mobile manipulator
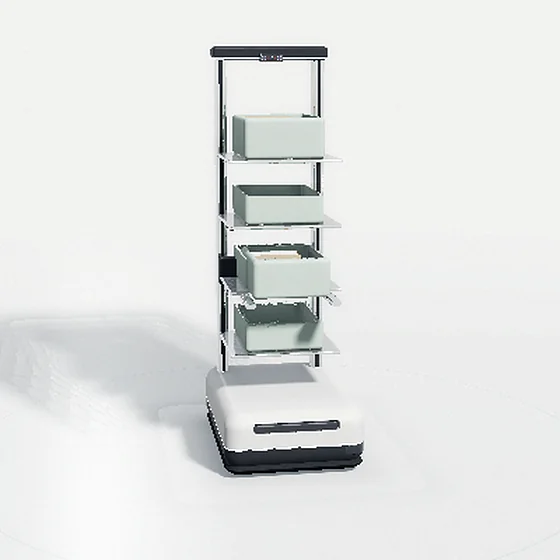 Tote-handling robot
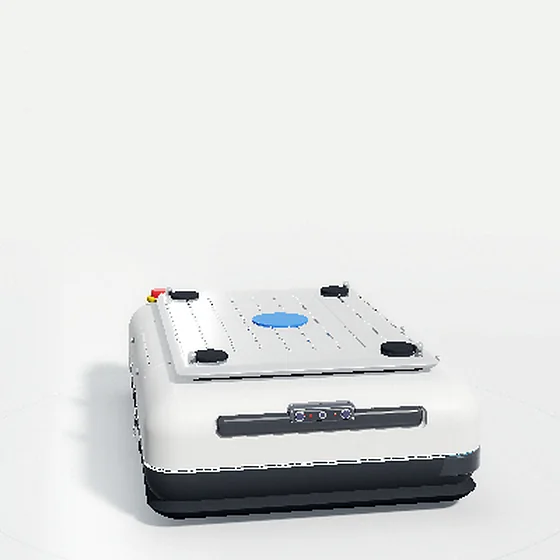 Lift AMR
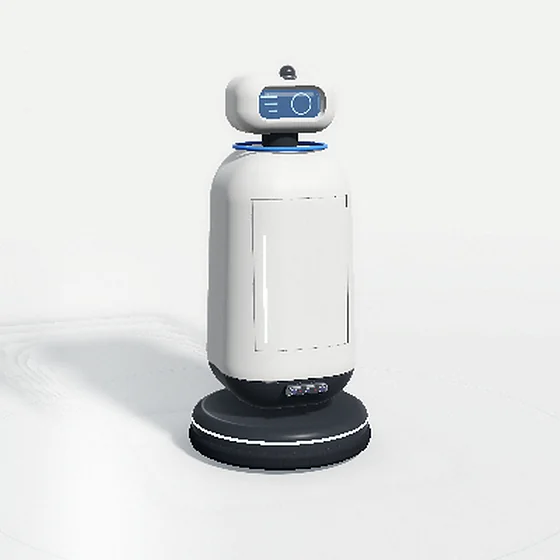 Hotel service robot
 Delivery robot
 Education robot
 Vision cobot cell
 Guide and inspection robot
Every hotspot on a concept points to a published hardware category. This is what to check before choosing one.
Stereo depth cameras turn two views into depth for grasping and obstacle checks.

A 360° DTOF LiDAR scans the space for mapping, localisation and obstacles.

An RK3588 edge box runs perception models and robot software on board.
Where each camera, LiDAR or compute module sits on the concepts. Select one to turn it in the viewer.


Scenes and robots are concept renderings for planning.
Open any concept in the viewer, or brief it directly.
Start an RFQ