TANNAIROBOTICS

Hardware

Four published products, ready to quote.

CompareBuyer guidesAll hardware

Robot Concepts

Eight robot concepts in 360°, configured per project.

Enter the showroom

Selection & Sourcing

Not sure which part fits, how to confirm it, or where to buy it? Choose a path. Product quotes stay free.

Find my pathSee sample workAbout TANNAI
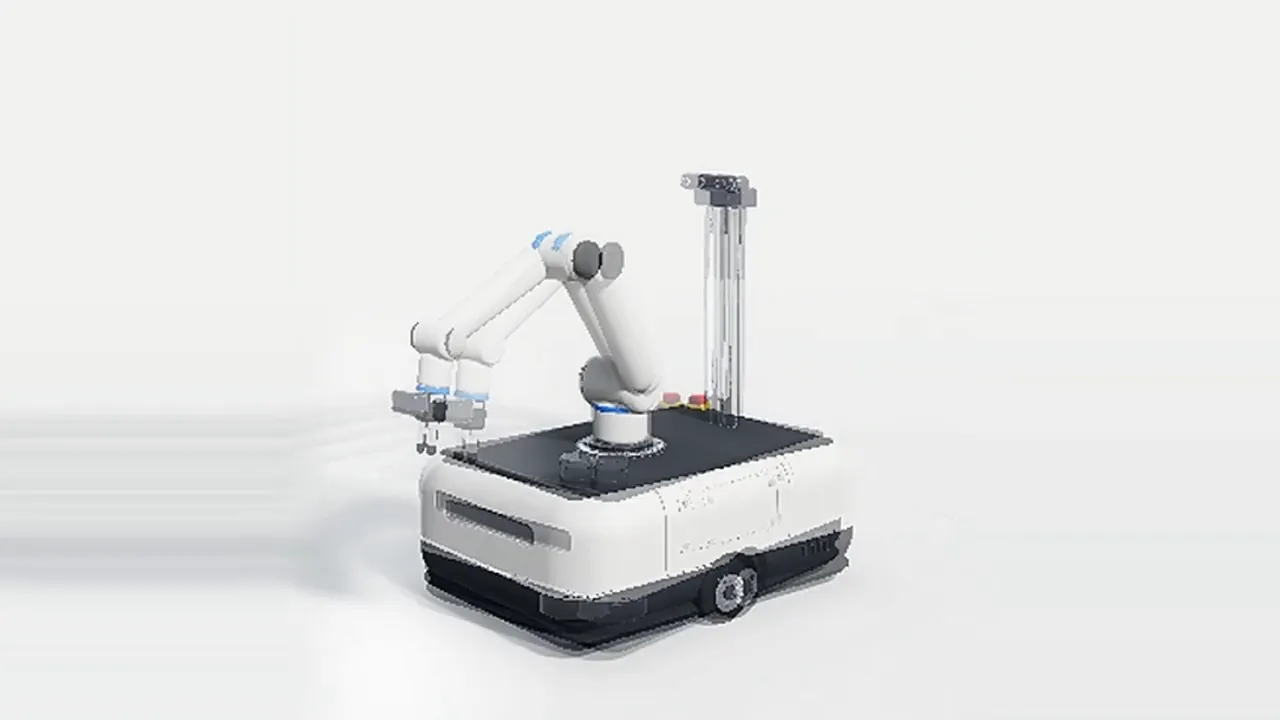
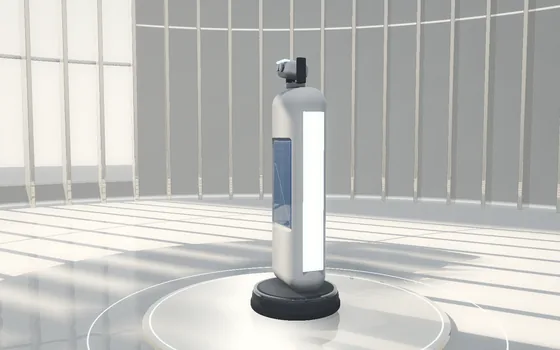
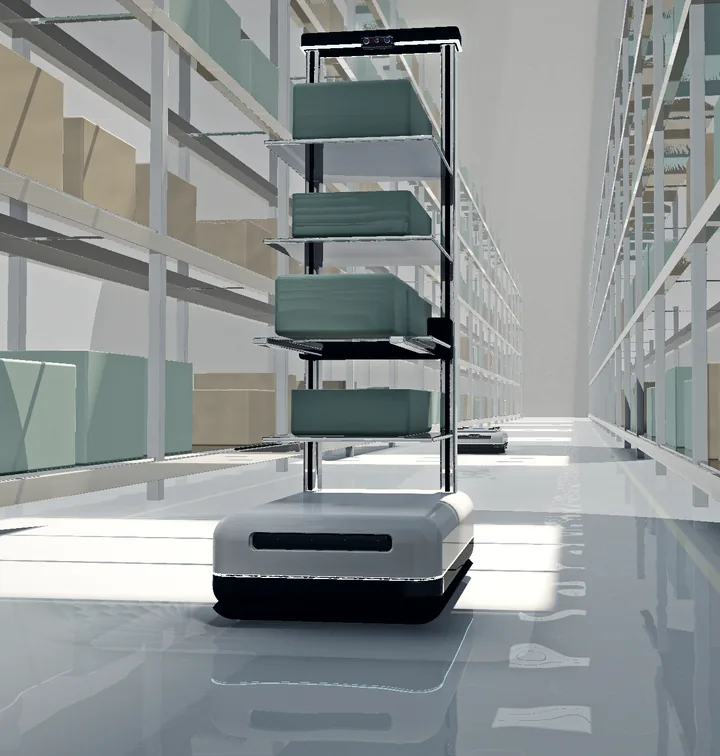
Concept rendering: Warehouse and logistics

Robot Applications

Concept scenes: where robots work, what they sense, and which hardware to evaluate.

Scene
Warehouse Flow
Robot concept
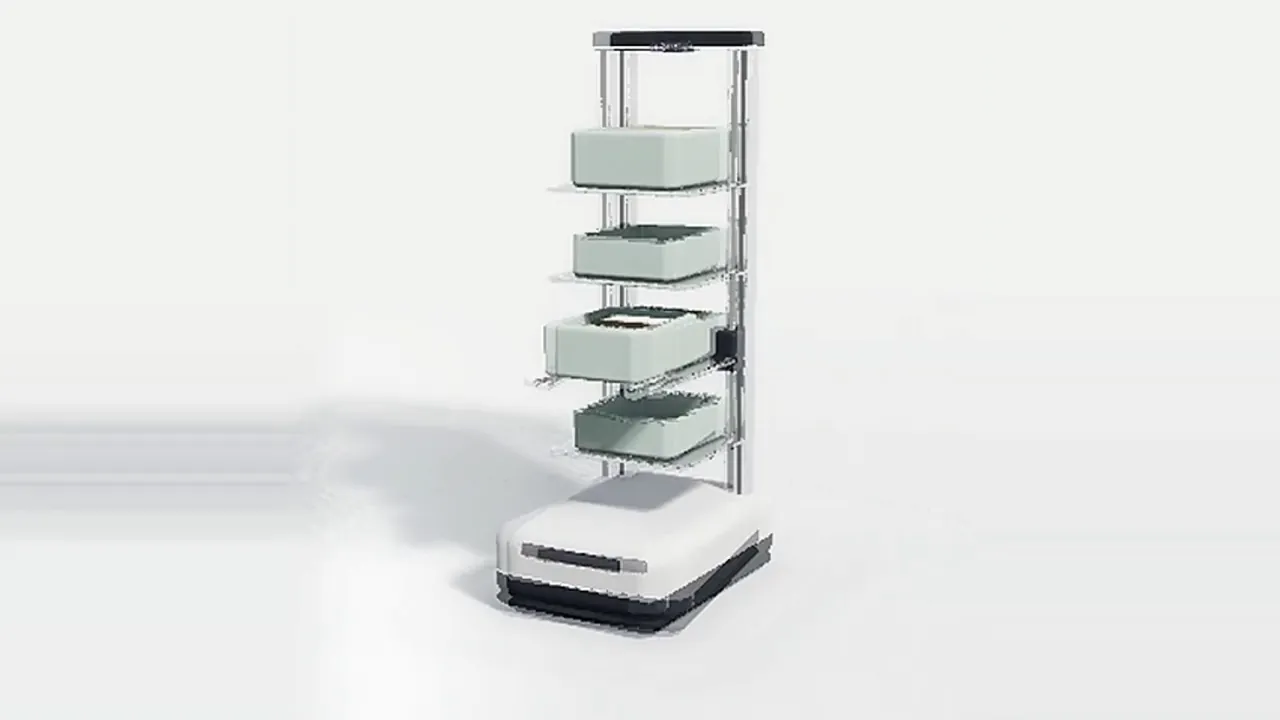
Tote-handling robot
Sensing
LiDAR & Perception · Vision & Depth Cameras · Edge AI & Computing
Concept rendering

Warehouse Flow

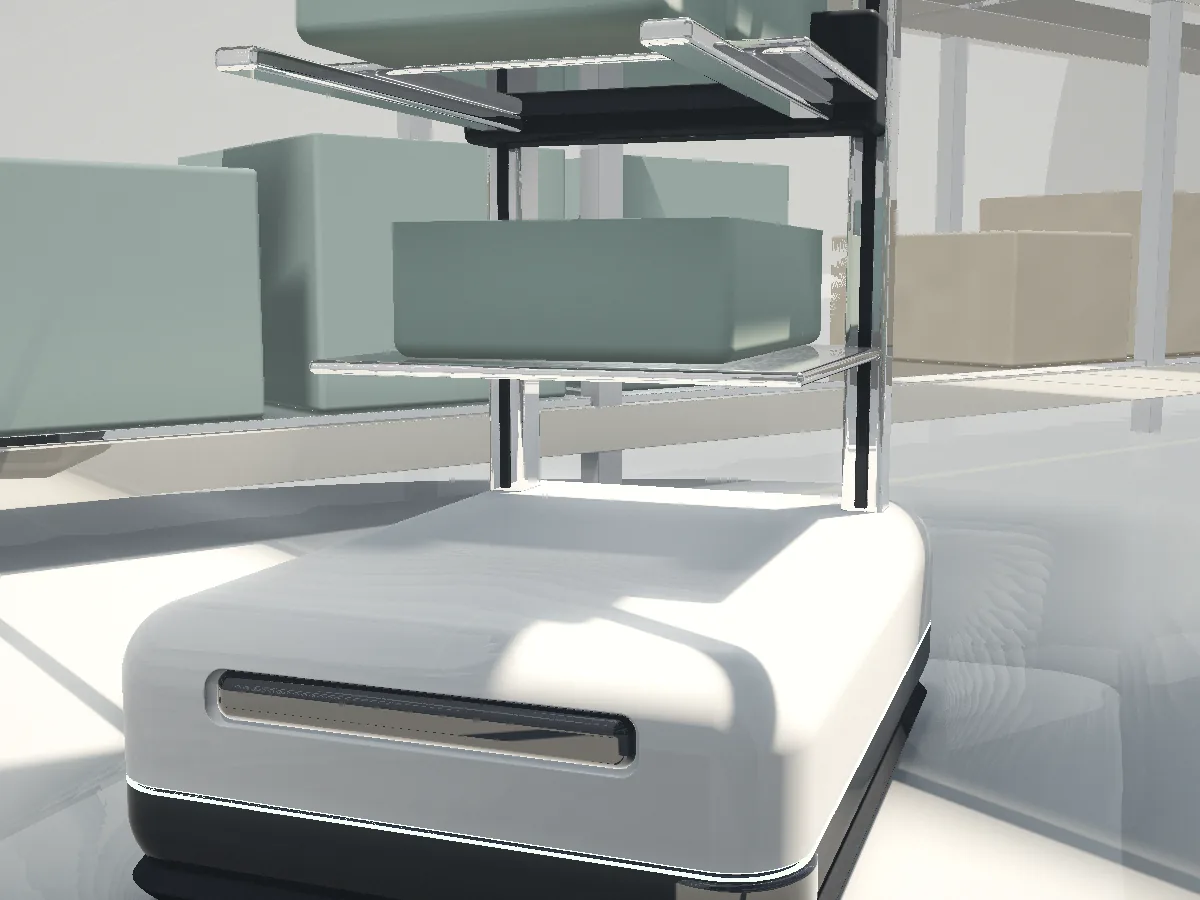
Bring totes to people, not people to shelves.

Concept rendering: Handling unit and mast camera
Handling unit and mast camera · Concept rendering

The task

  • Aisle navigation
  • Tote detection
  • Throughput

Where sensing gets hard

Narrow aisles, reflective floors and racks that change every shift.

Confirm first

  • How wide are the aisles, and how high are the racks?
  • Which tote sizes and weights move?
  • What throughput do you need per hour?
Brief this sceneReview this configurationOpen the robot concept
Illustration: TR-LID-D500
TR-LID-D500360-Degree DTOF LiDAR
Maximum range
12 m
Ranging accuracy
±10 mm
US$193Reference priceModel details
Concept rendering: Material handling
Scene
Material Moves
Robot concept
Lift AMR
Sensing
Vision & Depth Cameras · LiDAR & Perception
Concept rendering

Material Moves

Move carts, racks and pallets between stations without fixed conveyors.

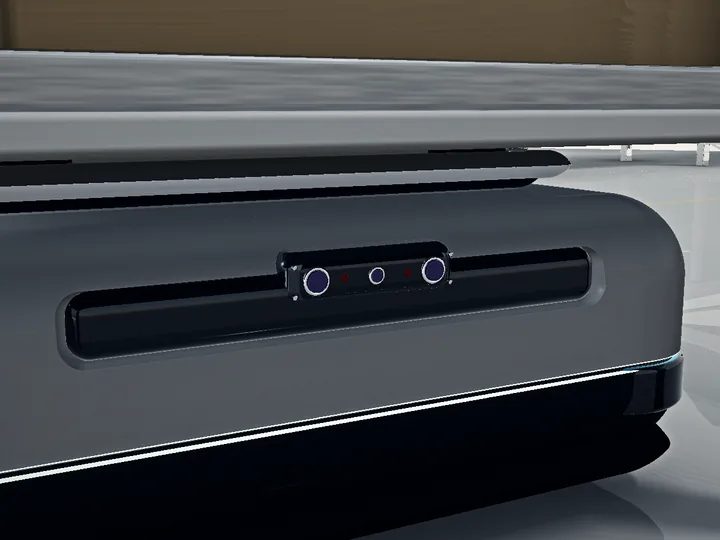
Concept rendering: Front depth camera under the load
Front depth camera under the load · Concept rendering

The task

  • Payload and lift height
  • Docking accuracy
  • Fleet traffic

Where sensing gets hard

Loads change weight between stations, and docking has to repeat to the centimetre.

Confirm first

  • What does a cart or rack weigh when loaded?
  • How precise must docking be at each station?
  • How many robots share the floor?
Brief this sceneReview this configurationOpen the robot concept
Illustration: TR-CAM-S4M
TR-CAM-S4M4MP Synchronized Stereo Depth Module
Sensor resolution
4 MP
Interface
USB 2.0, driver-free
US$103Reference priceModel details
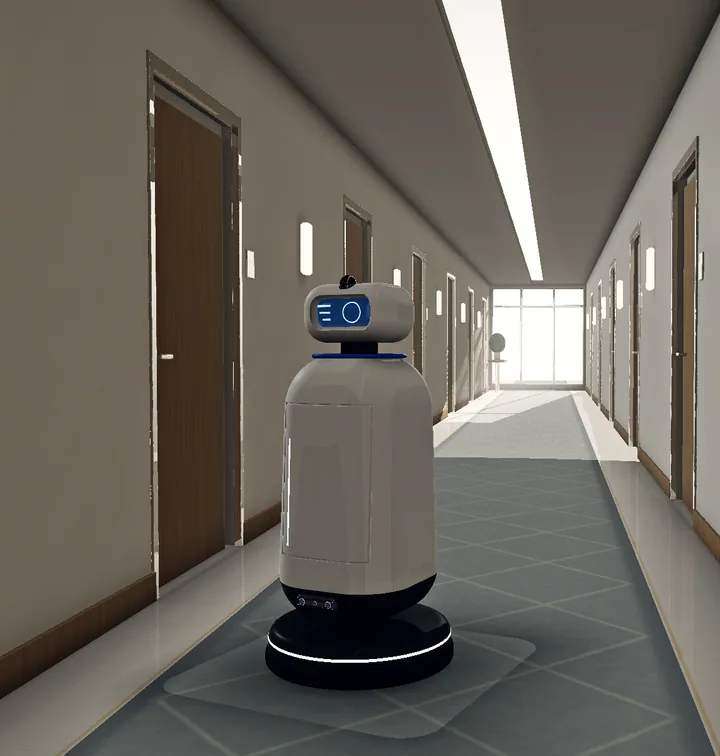
Concept rendering: Hotel service
Scene
Hotel Service
Robot concept
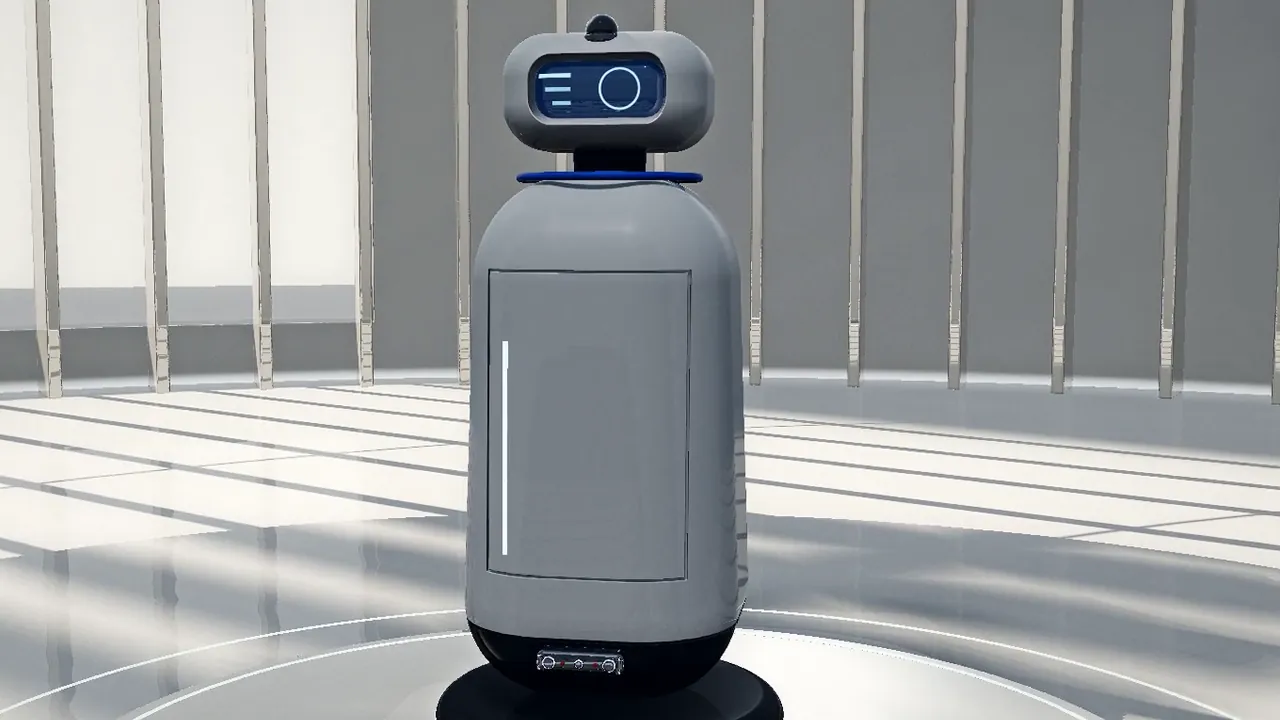
Hotel service robot
Sensing
Vision & Depth Cameras · LiDAR & Perception · Edge AI & Computing
Concept rendering

Hotel Service

Deliver to rooms across corridors, lifts and doors.

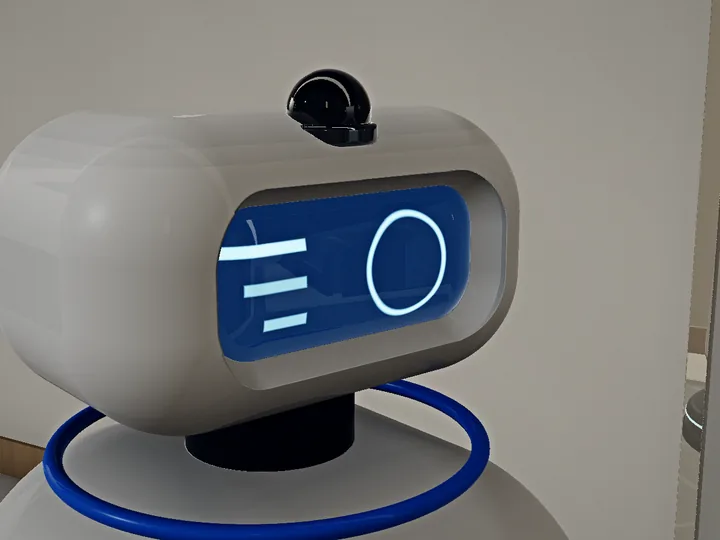
Concept rendering: Head screen and top camera
Head screen and top camera · Concept rendering

The task

  • Lift and door integration
  • Quiet operation
  • Guest interaction

Where sensing gets hard

Doors, lifts and guests: navigation that stays quiet and predictable.

Confirm first

  • Which lifts and doors must the robot operate?
  • Quiet hours and noise limits?
  • How does a guest confirm the delivery?
Brief this sceneReview this configurationOpen the robot concept
Illustration: TR-CAM-U4M
TR-CAM-U4M4MP USB2.0 Driver-Free Stereo Camera
Sensor resolution
2 x 1080p (3840 x 1080 combined, 4 MP)
Interface
USB 2.0, driver-free
US$166Reference priceModel details
Concept rendering: Delivery and navigation
Scene
Delivery Routes
Robot concept
Delivery robot
Sensing
Vision & Depth Cameras · LiDAR & Perception
Concept rendering

Delivery Routes

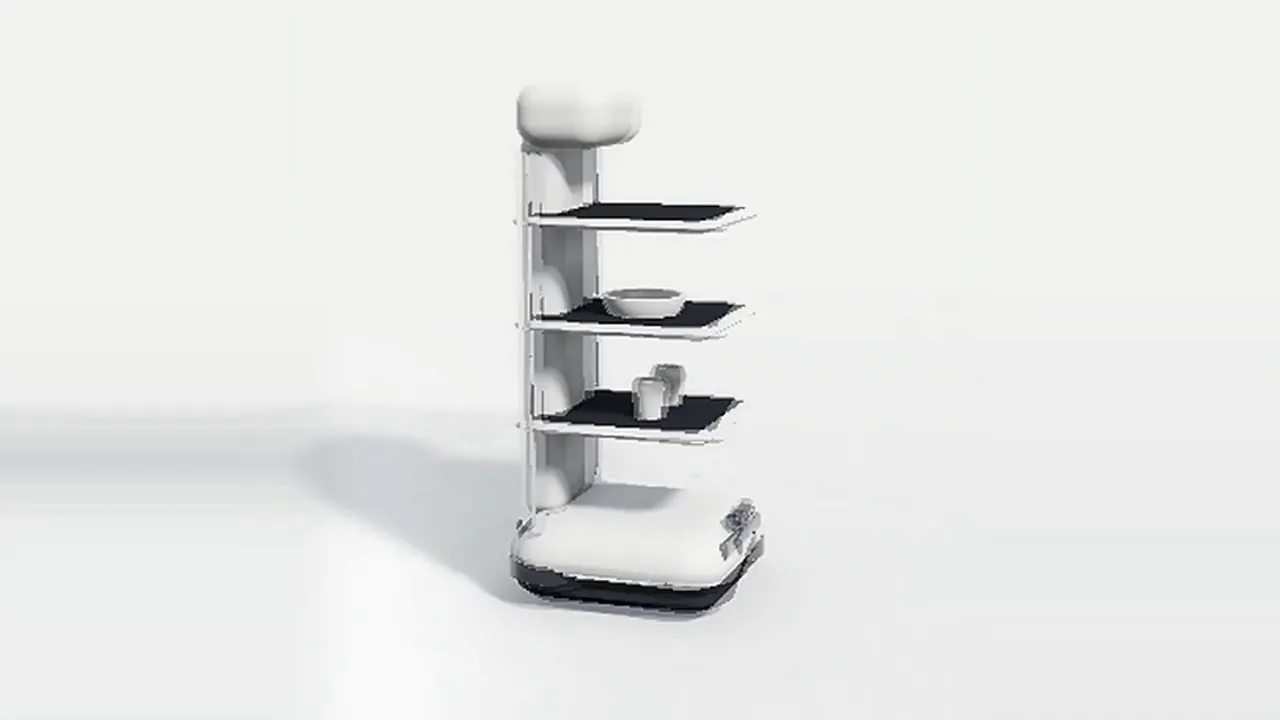
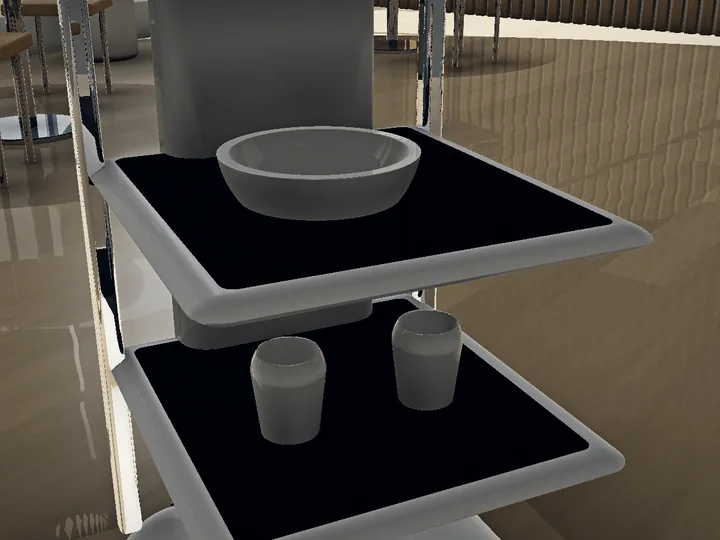
Cross a busy floor with three trays and no collisions.

Concept rendering: Delivery trays
Delivery trays

The task

  • Obstacle avoidance
  • Narrow passages
  • Battery and charging

Where sensing gets hard

Chairs move, guests stop without warning and trays must stay level.

Confirm first

  • How narrow is the tightest passage?
  • Peak-hour traffic and obstacles?
  • Charging between shifts?

Hardware to evaluate

Concept rendering: Education and STEM
Scene
STEM Labs
Robot concept
Education robot
Sensing
Vision & Depth Cameras · LiDAR & Perception
Concept rendering

STEM Labs

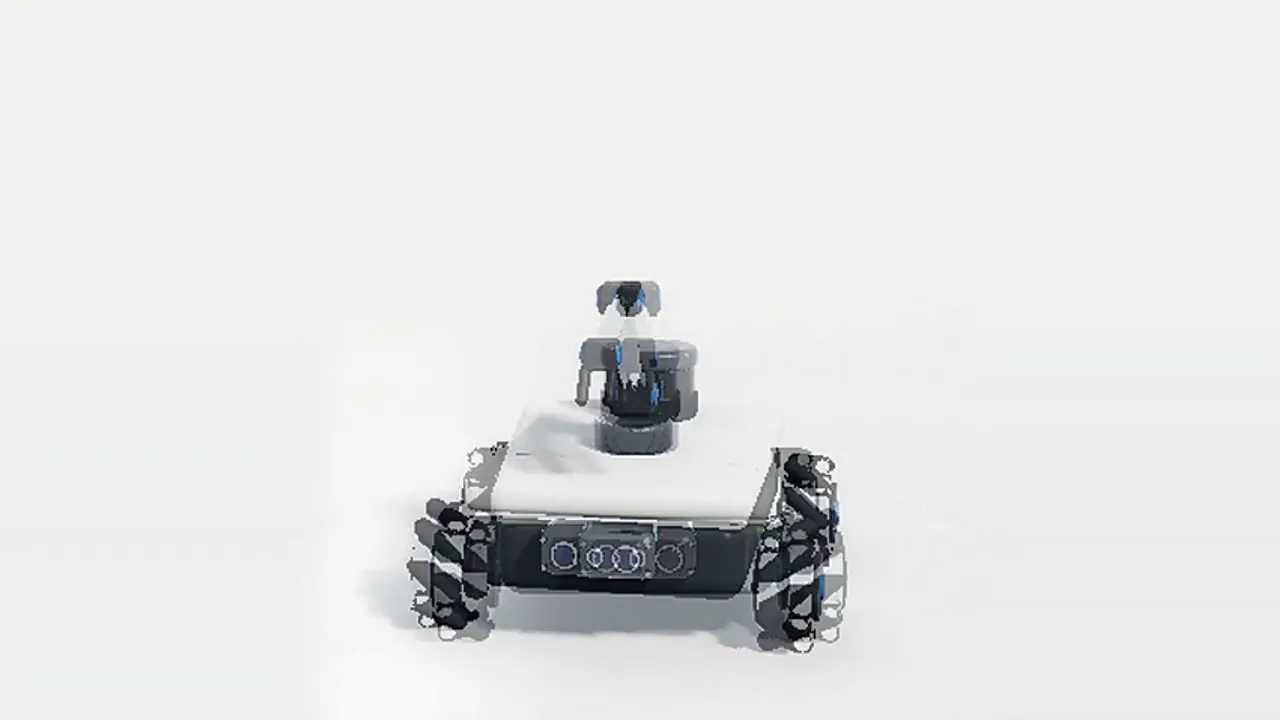
Teach calibration, mapping and pick-and-place on one bench.

Concept rendering: Mecanum base and teaching arm
Mecanum base and teaching arm

The task

  • ROS 2 support
  • Open SDK
  • Classroom safety

Where sensing gets hard

Students change the setup every lesson; the robot must stay safe and easy to reset.

Confirm first

  • ROS 2 or another stack in class?
  • How many students per robot?
  • Which safety rules apply in the classroom?

Hardware to evaluate

Concept rendering: Research and lab
Scene
Research Lab
Robot concept
Mobile manipulator
Sensing
Vision & Depth Cameras · Edge AI & Computing
Concept rendering

Research Lab

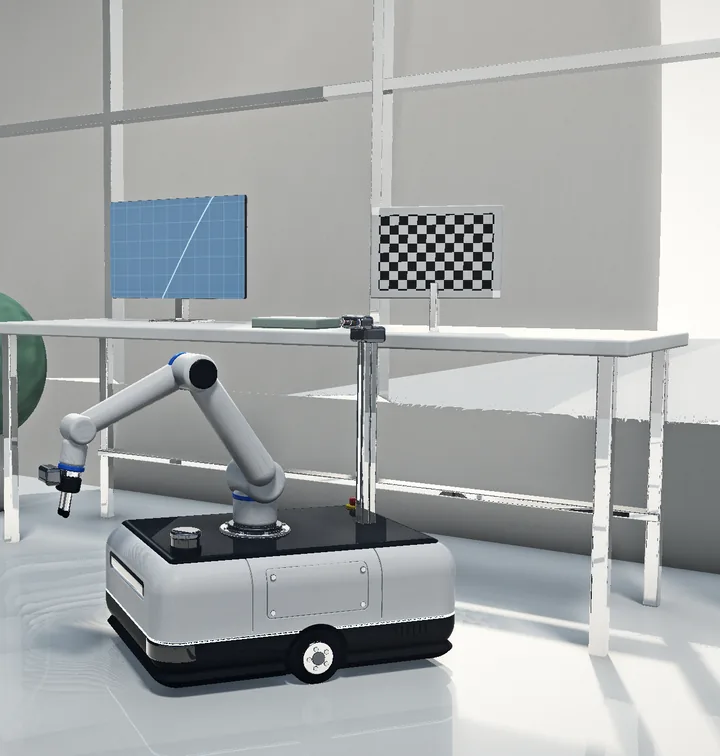
Calibrate, log and reproduce experiments with a mobile arm.

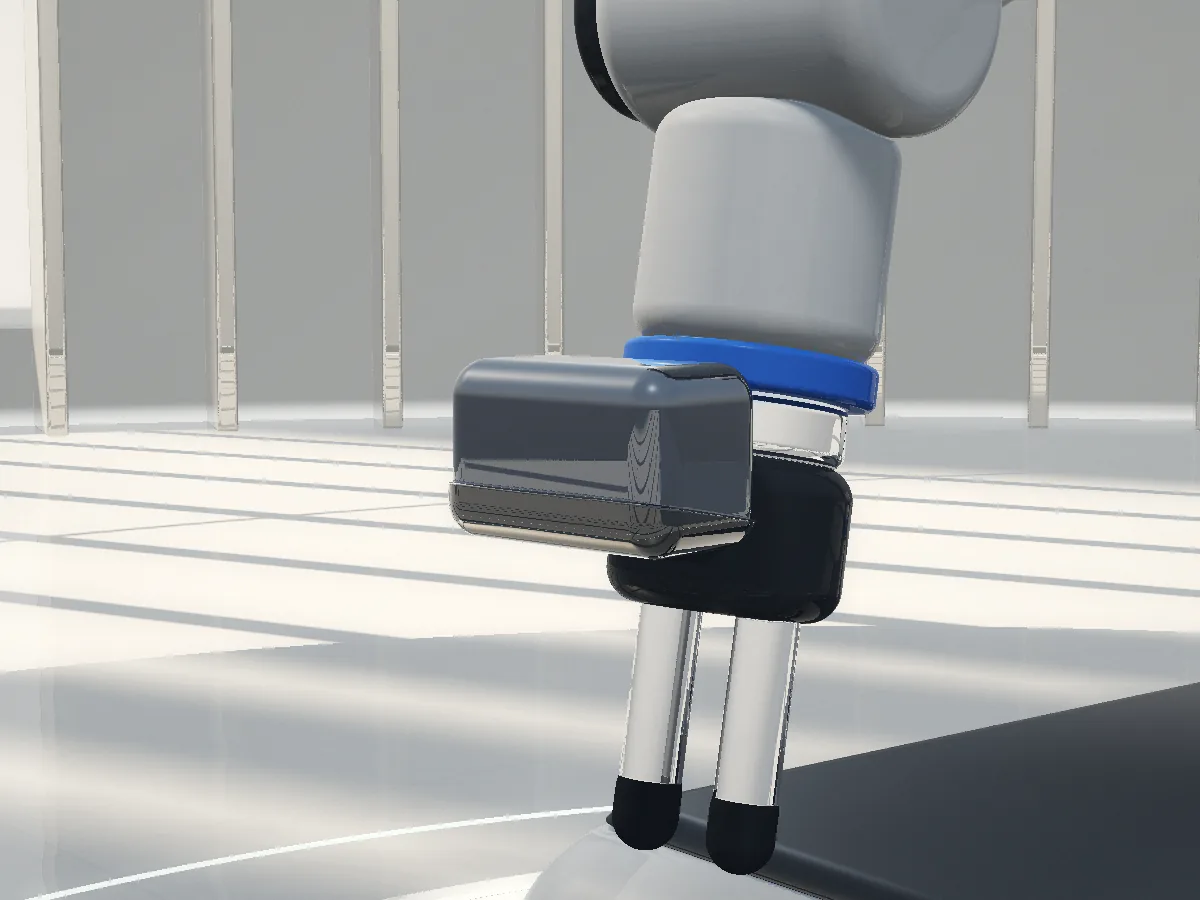
Concept rendering: Wrist camera at the grasp
Wrist camera at the grasp · Concept rendering

The task

  • Sensor timing
  • Calibration
  • Data logging

Where sensing gets hard

Experiments must repeat: calibration, timing and logged data.

Confirm first

  • Which sensors need time synchronisation?
  • Calibration routine and targets?
  • How are runs logged and replayed?
Brief this sceneReview this configurationOpen the robot concept
Illustration: TR-EDGE-3588
TR-EDGE-3588Tannai Robotics RK3588 AI Box
SoC
Rockchip RK3588
Interfaces
Ethernet, HDMI
US$672Reference priceModel details
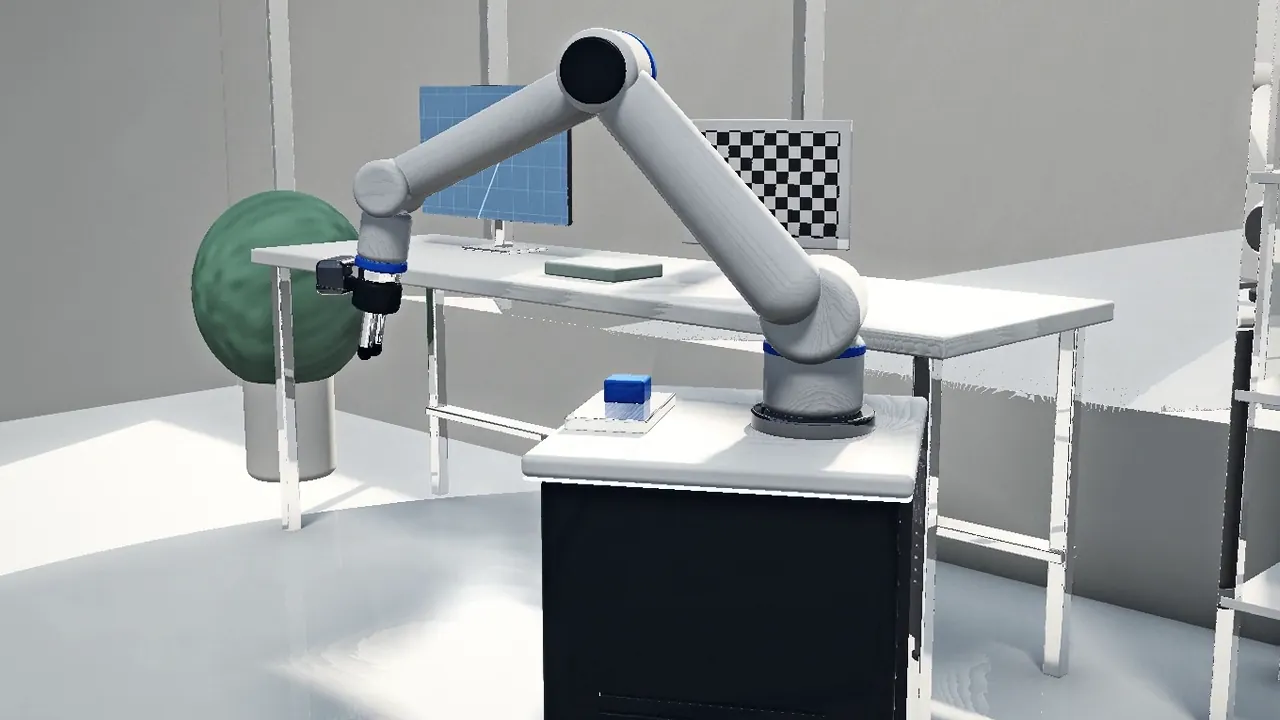
Concept rendering: Industrial vision and manipulation
Scene
Vision Cells
Robot concept
Vision cobot cell
Sensing
Vision & Depth Cameras · Edge AI & Computing
Concept rendering

Vision Cells

Find, grasp and place parts with vision at the line.

Concept rendering: Wrist camera above the part
Wrist camera above the part

The task

  • Depth accuracy
  • Cycle time
  • Lighting robustness

Where sensing gets hard

Parts arrive at speed; the camera must find pose and surface in one frame.

Confirm first

  • Part size, surface and tolerance?
  • Target cycle time?
  • Lighting at the line?

Hardware to evaluate

Concept rendering: Inspection and guidance
Scene
Guide & Patrol
Robot concept
Guide and inspection robot
Sensing
Vision & Depth Cameras · Edge AI & Computing
Concept rendering

Guide & Patrol

Guide visitors and patrol spaces with cameras and a screen.

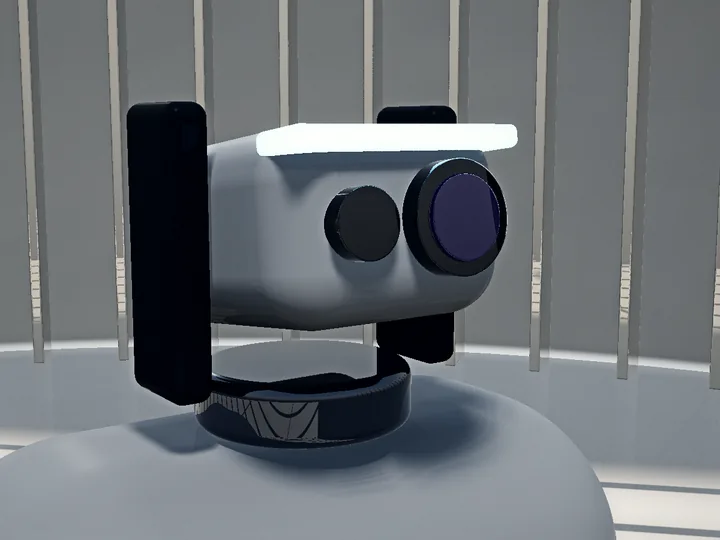
Concept rendering: Pan-tilt camera head
Pan-tilt camera head

The task

  • Localisation
  • Camera coverage
  • Remote monitoring

Where sensing gets hard

Open spaces, changing daylight and people at every distance.

Confirm first

  • Which areas and floors must be covered?
  • Camera coverage and recording rules?
  • Who monitors remotely?

Hardware to evaluate

From Brief to Fit

Five choices draft a checklist we verify with you. It is not a quotation and never a compatibility promise.

01Application
02Environment
03Host connection
04Project stage
05Timing
Selection checklistExample choices — change any step.
Draft · to verify
Scene
In motion
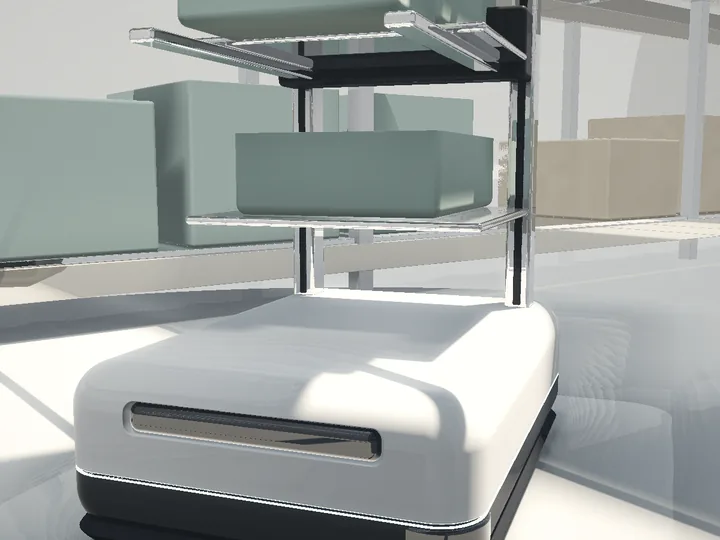
Close-up
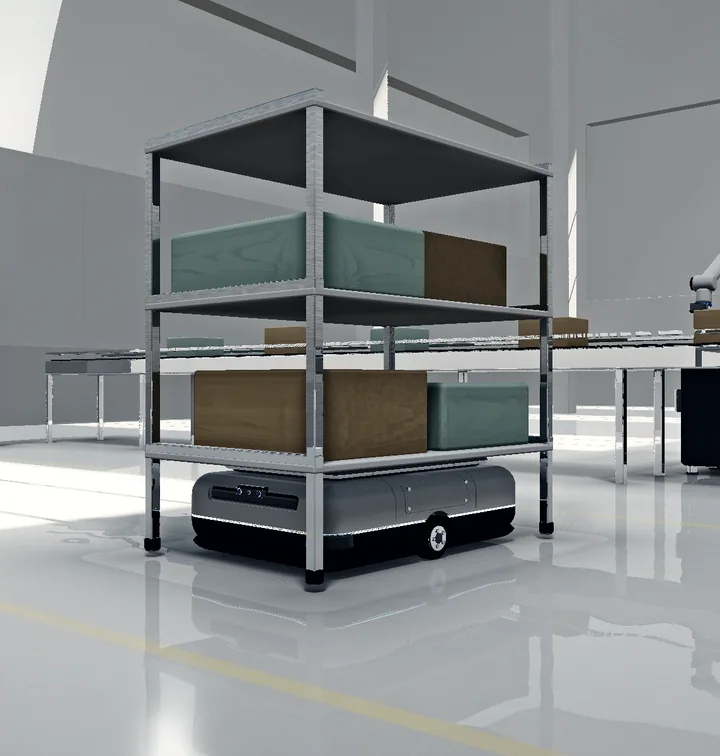
Application
Environment
Host connection
Project stage
Timing

AHardware to evaluate

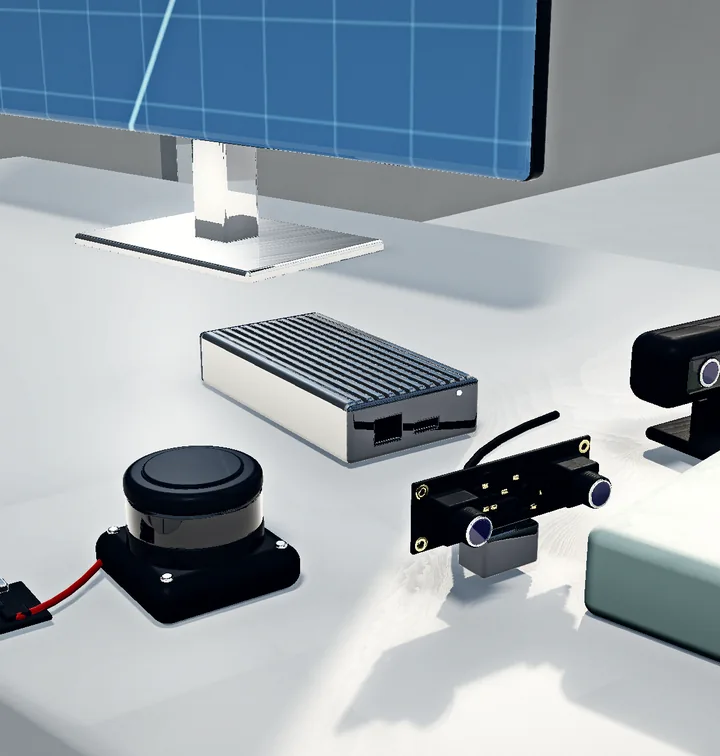
  • TR-EDGE-3588Tannai Robotics RK3588 AI BoxEthernet, HDMI
    Spec sheet
  • TR-LID-D500360-Degree DTOF LiDARSerial (UART) via included USB adapter board
    Spec sheet
  • TR-CAM-U4M4MP USB2.0 Driver-Free Stereo CameraUSB 2.0, driver-free
    Spec sheet
  • TR-CAM-S4M4MP Synchronized Stereo Depth ModuleUSB 2.0, driver-free
    Spec sheet

BCheck before quoting

  • USB: both cameras list USB 2.0, driver-free; the LiDAR connects through its included UART-to-USB adapter board. Confirm the driver on your host OS.
  • Indoor: note the lighting, any glass or reflective floors, and the narrowest passage.
  • Pilot: agree acceptance criteria before the sample or POC starts.
  • Requested timing: 1–3 months. Availability and lead time are confirmed in the quotation.
  • How wide are the aisles, and how high are the racks?
  • Which tote sizes and weights move?
  • What throughput do you need per hour?

CWhat happens next

  1. Requirement analysis
  2. Candidate options
  3. Specification check
  4. Sample / POC
  5. Quotation & delivery

Not Listed Here?

Describe the environment and the task. We will map the perception and compute it needs.

Scenes and robots are concept renderings for planning.

Start an RFQ
Motion preview · 0:11

Warehouse robotics

What a robot in a racked aisle senses, and how it plans.

Concept motion preview · silent
0:00 / 0:11
Motion preview · 0:11

Material handling robots

Linking conveyors, workcells and storage into one flow.

Concept motion preview · silent
0:00 / 0:11
Motion preview · 0:11

Hotel service robots

Corridor, lift and door: what the building must provide.

Concept motion preview · silent
0:00 / 0:11
Motion preview · 0:11

Autonomous navigation and delivery

Crossing a busy service floor without collisions.

Concept motion preview · silent
0:00 / 0:11
Motion preview · 0:11

Education robots

From calibration to pick-and-place to mapping on one bench.

Concept motion preview · silent
0:00 / 0:11
Motion preview · 0:11

Research and lab robotics

Calibration, point clouds, sensor timing and reproducible logs.

Concept motion preview · silent
0:00 / 0:11
Motion preview · 0:11

Industrial vision and grasping

Overhead stereo, a grasp and a place check at the line.

Concept motion preview · silent
0:00 / 0:11